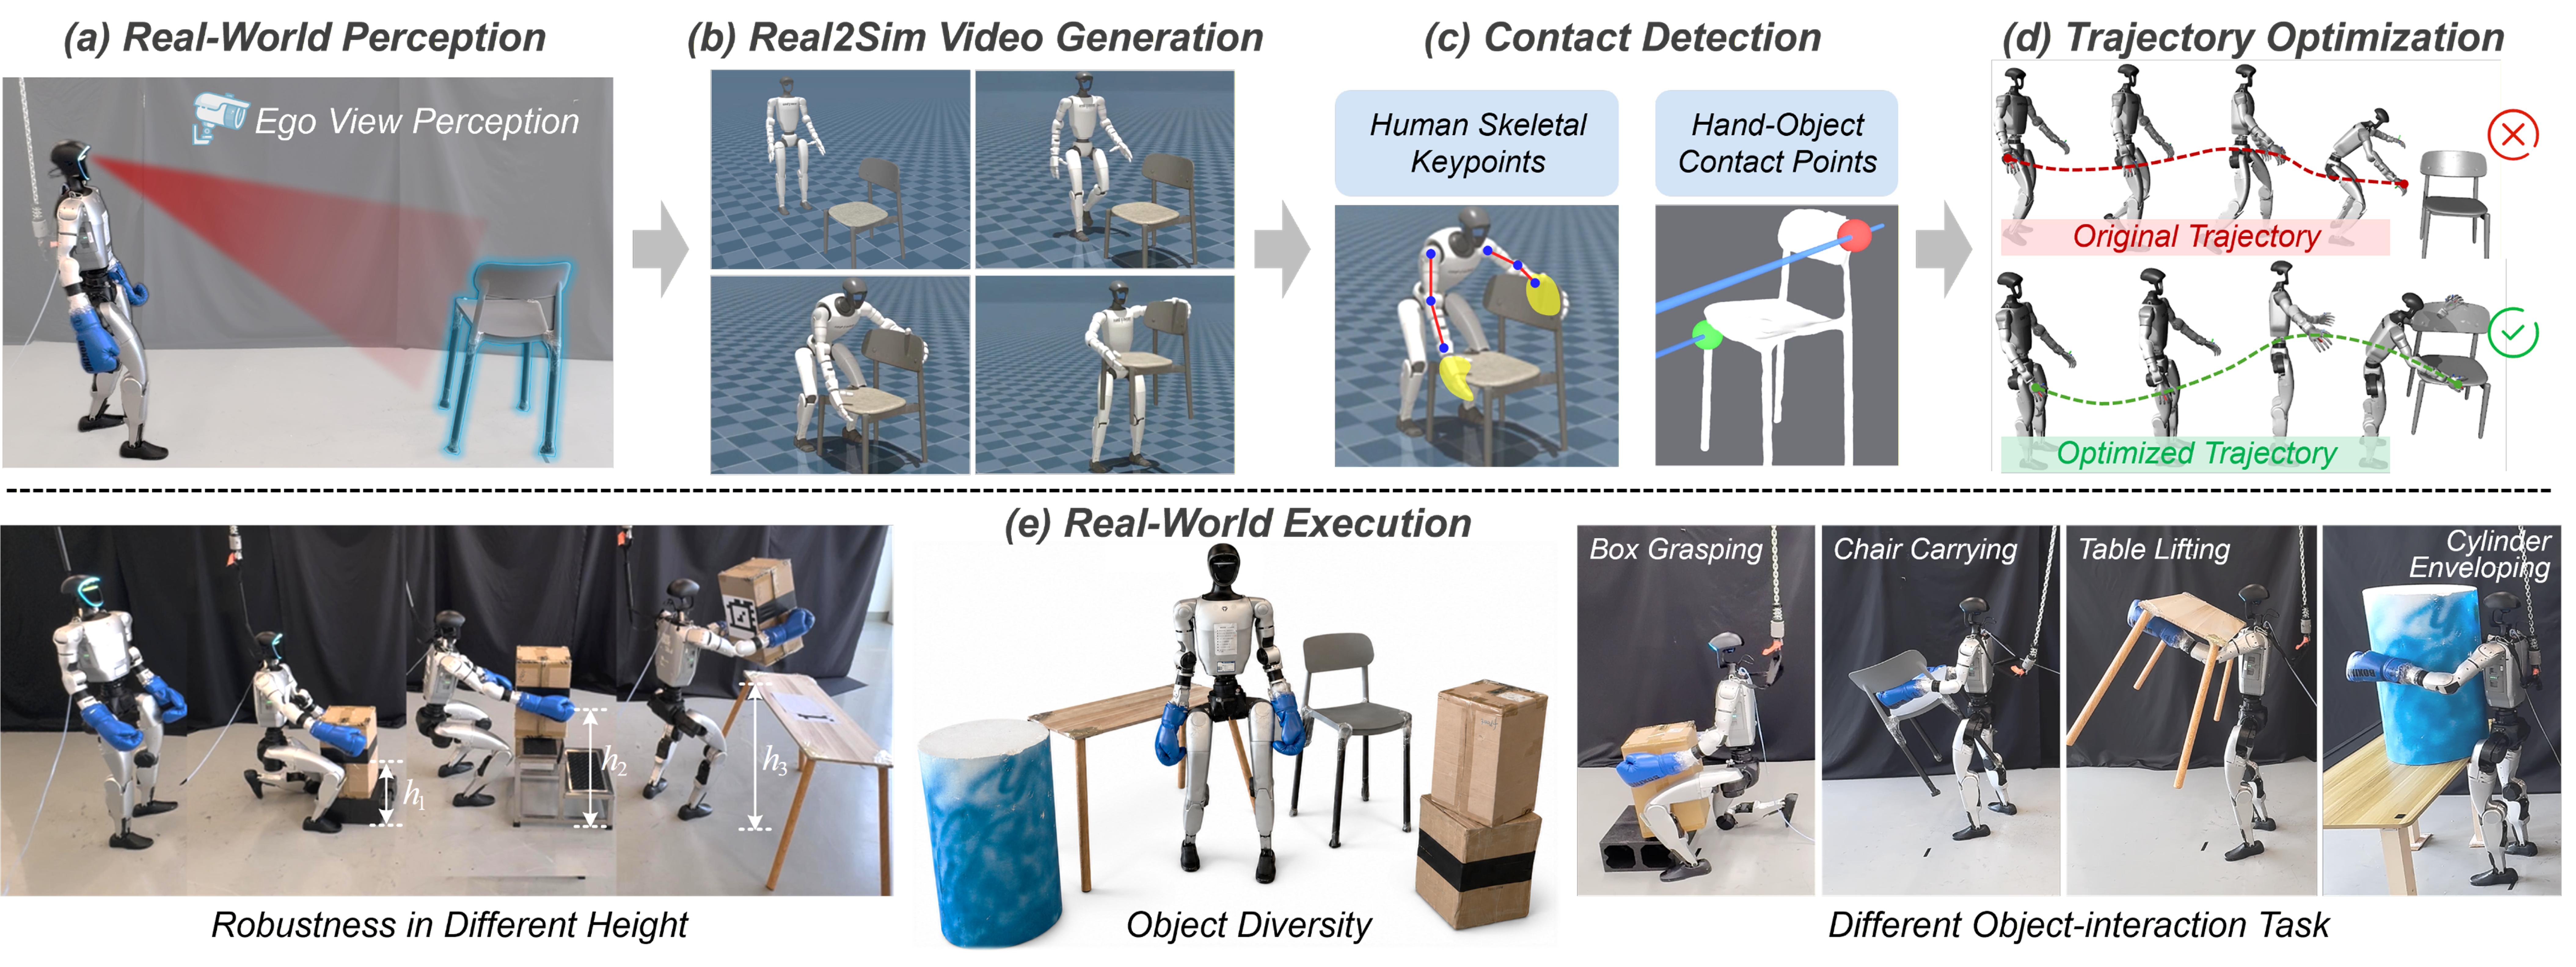
GenHOI: Contact-Aware Humanoid-Object Interaction by Imitating Generated Videos without Task-Specific Training
Preprint, 2026
Humanoid-Object Interaction by Imitating Generated Videos.
I am a PhD student at the Hong Kong University of Science and Technology (Guangzhou), supervised by Jun Ma and Michael Yu Wang. Previously, I received my master's degree from the Institute of AI and Robotics at Fudan University in 2024, supervised by Hongbin Fang, and my bachelor's degree in Robot Engineering from Southeast University in 2021.
I am broadly interested in the full robotics stack, with experience in high-fidelity dynamics modeling, motion planning, whole-body control, and reinforcement learning. My current research focuses on loco-manipulation, particularly long-horizon, multi-contact interactions between humanoid robots and diverse objects. I aim to extend robotic capabilities beyond tabletop pick-and-place tasks, enabling robots to assist people with complex physical tasks and reduce human workload.
Preprint, 2026
Humanoid-Object Interaction by Imitating Generated Videos.
IEEE Transactions on Robotics (T-RO), 2026 (Accepted)
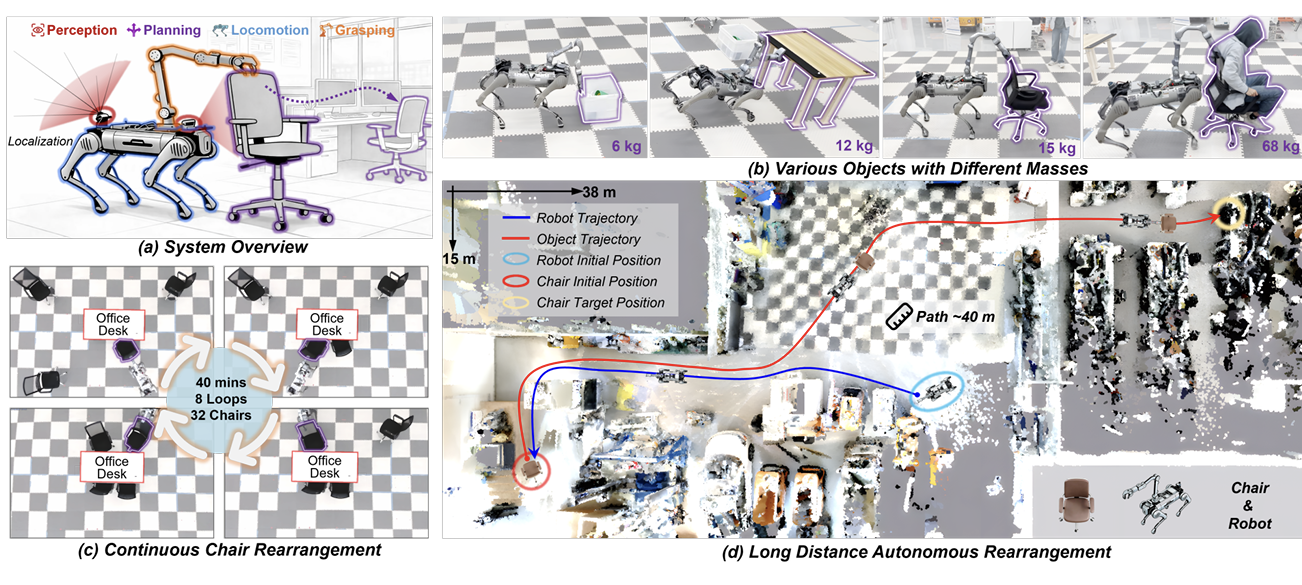
Autonomous Large-Object Rearrangement with a Legged Manipulator.
Submitted to TRO
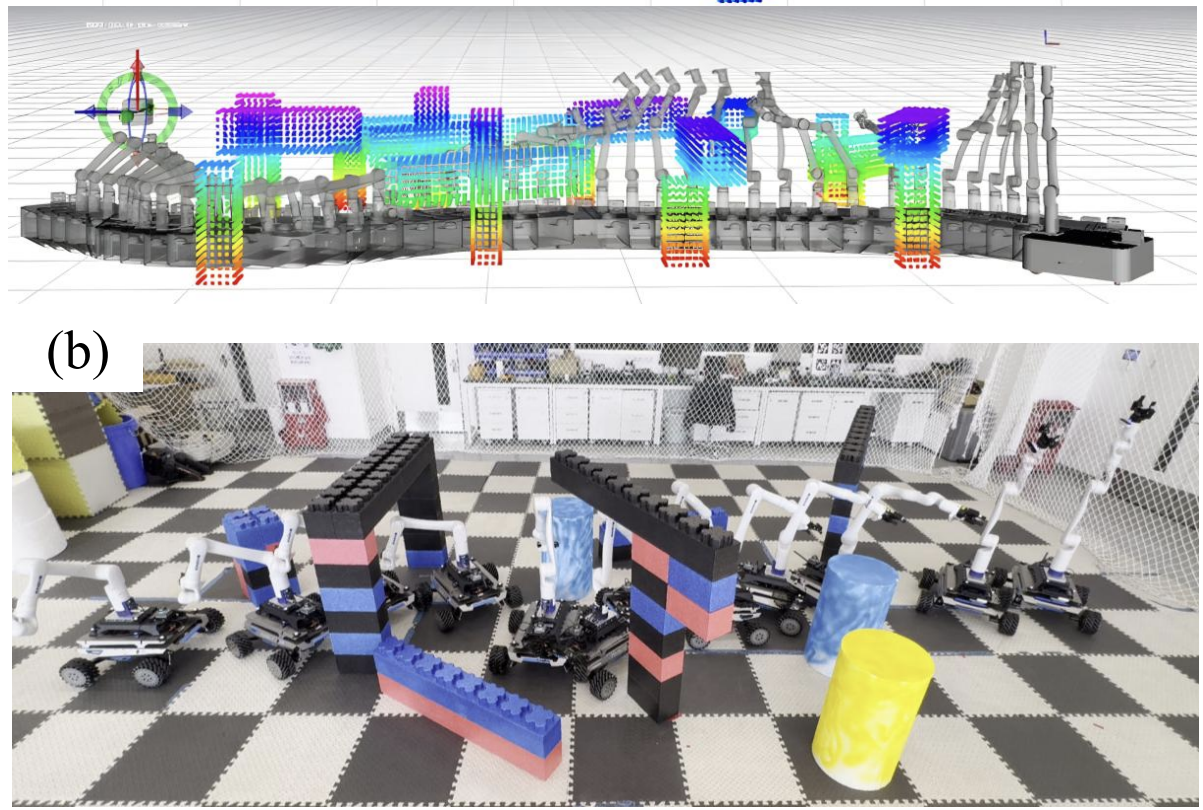
Fast and safe trajectory optimization for mobile manipulators with neural configuration space distance field.
IEEE Robotics and Automation Letters (RA-L), 2026
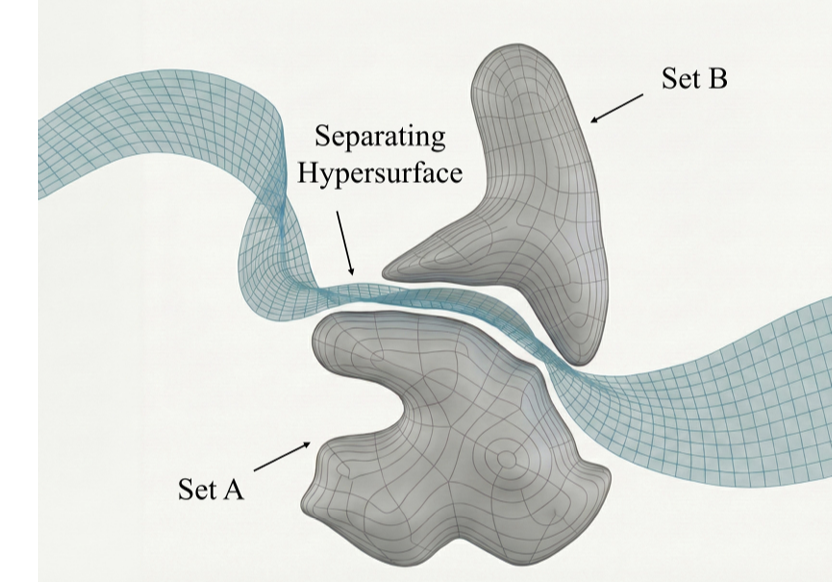
Online trajectory optimization for arbitrary-shaped mobile robots via polynomial separating hypersurfaces.
ICRA , 2026
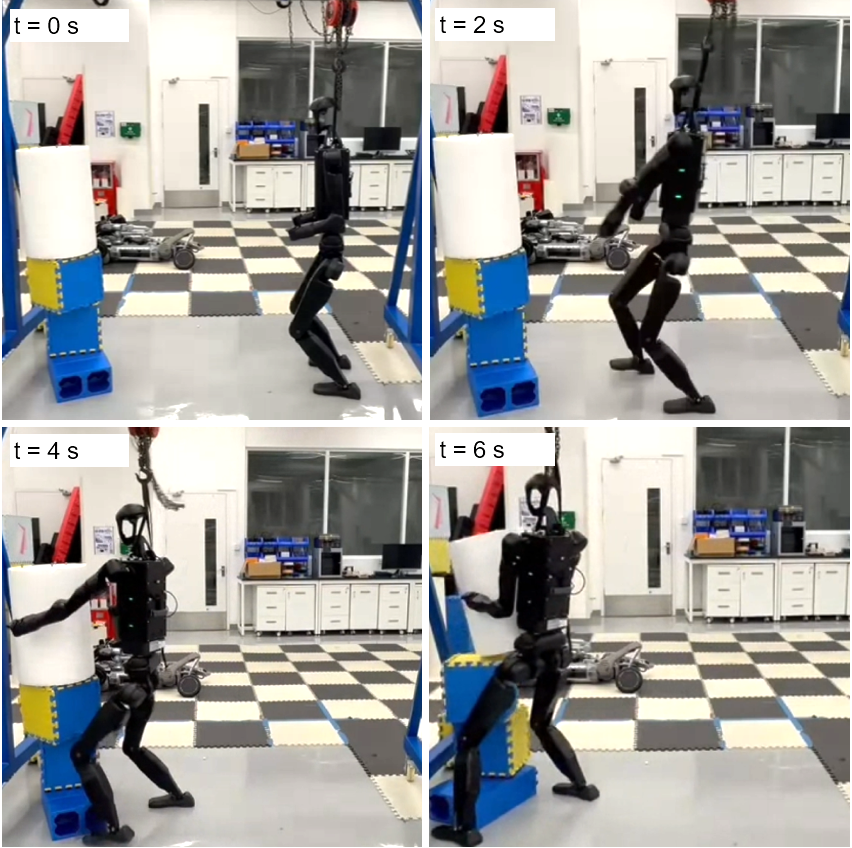
Embracing Bulky Objects with Humanoid Robots using WBC.
Submitted to T-Mech , 2025
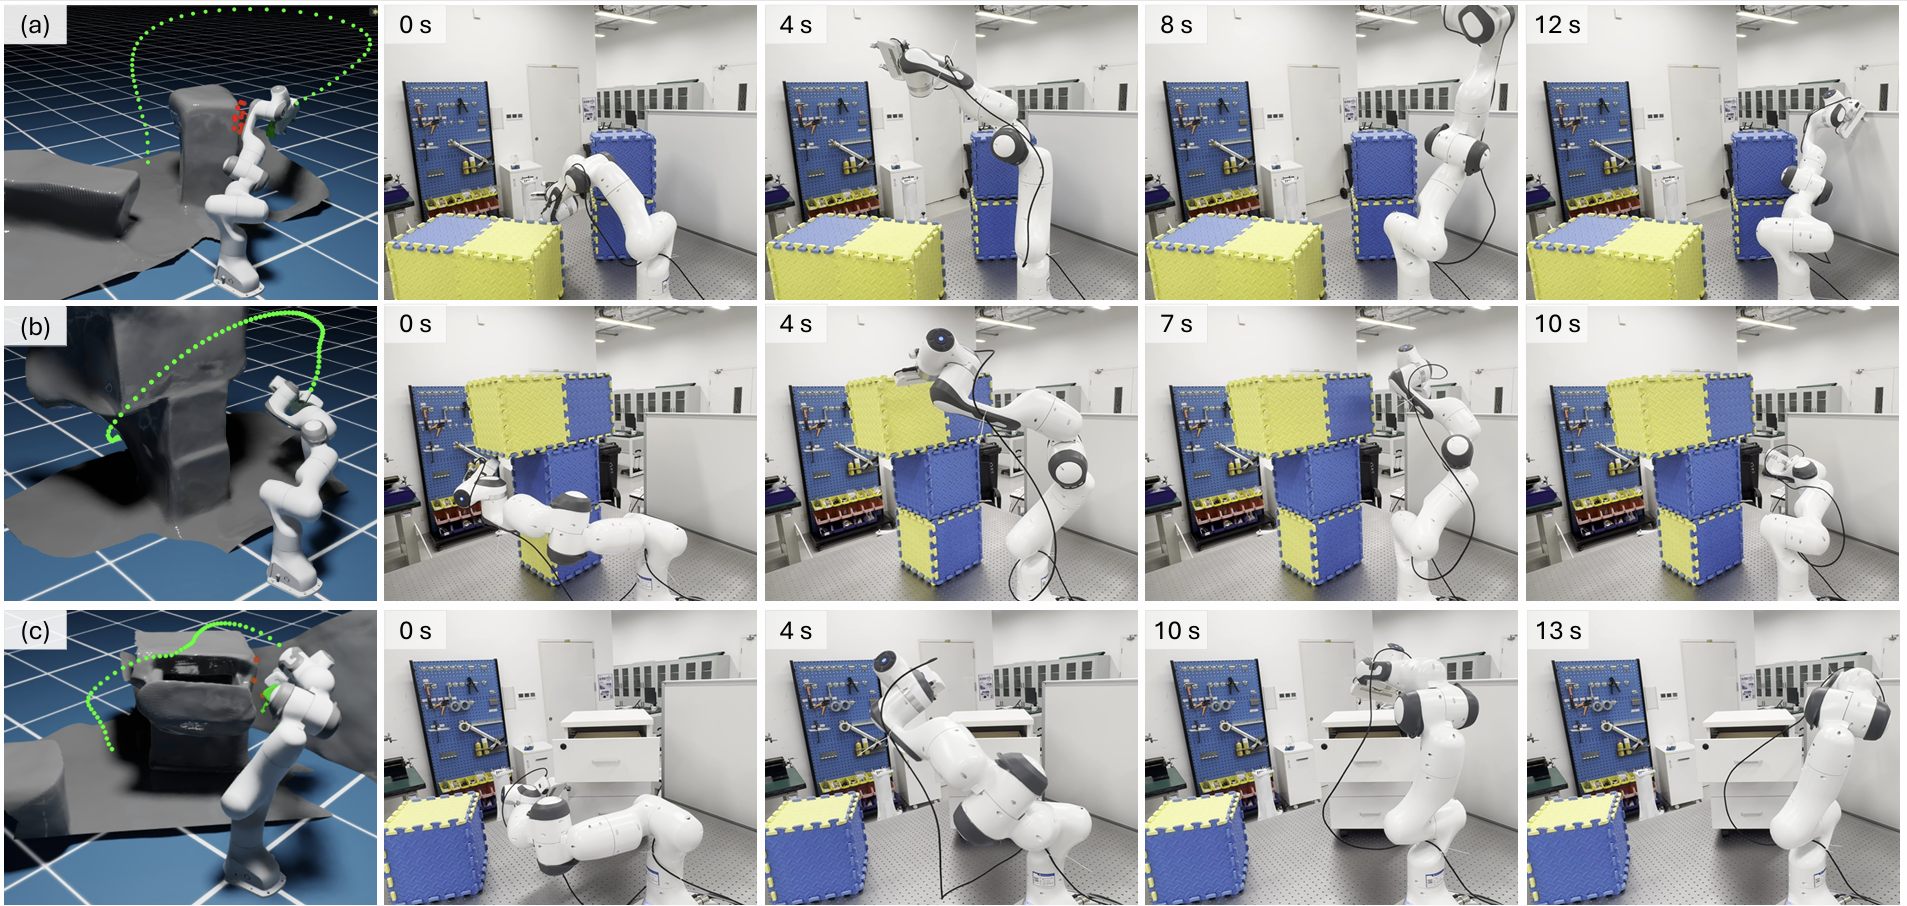
Encodes the environment and the manipulator using signed distance field.
IEEE Robotics and Automation Letters (RA-L), 2025
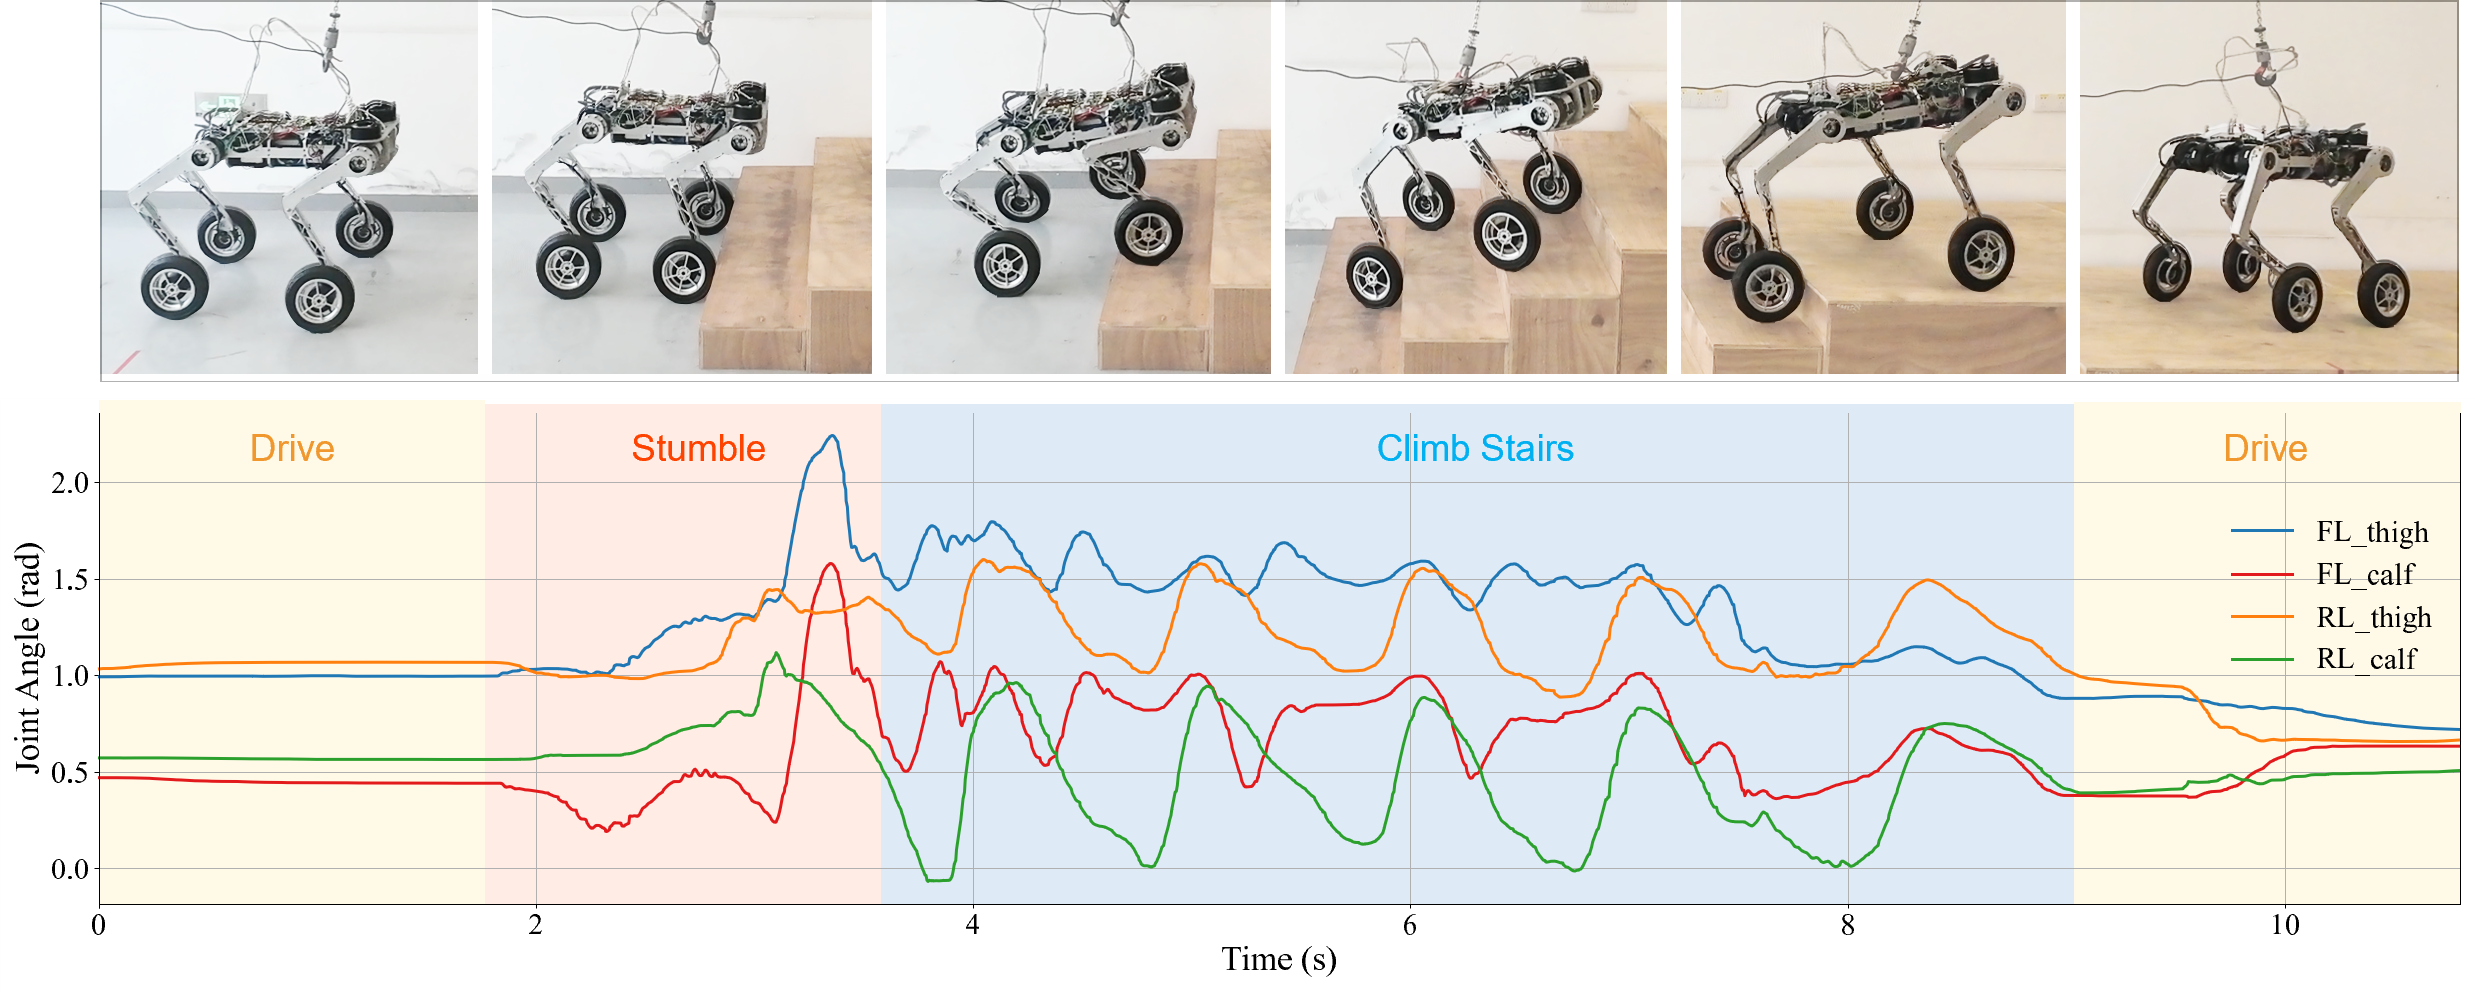
Design and RL locomotion for Reconfigured Wheel-Legged Robot
The International Journal of Robotics Research (IJRR). Top , 2025
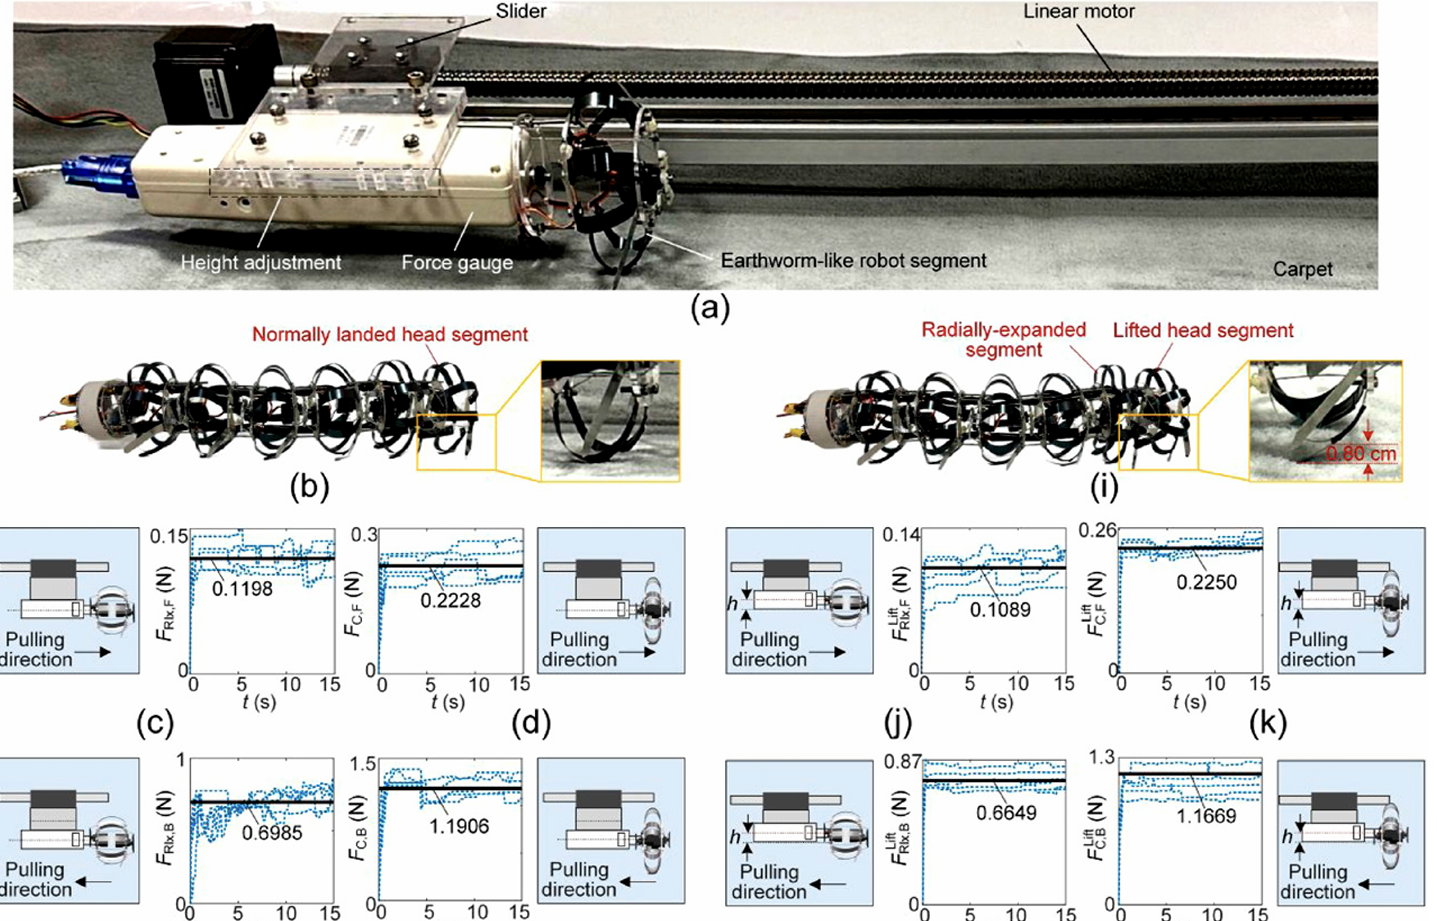
Accurate dynamics modeling for worm-like robot

IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) , 2025
Best Paper Award on Mobile Manipulation
Best Student Paper Award Finalist
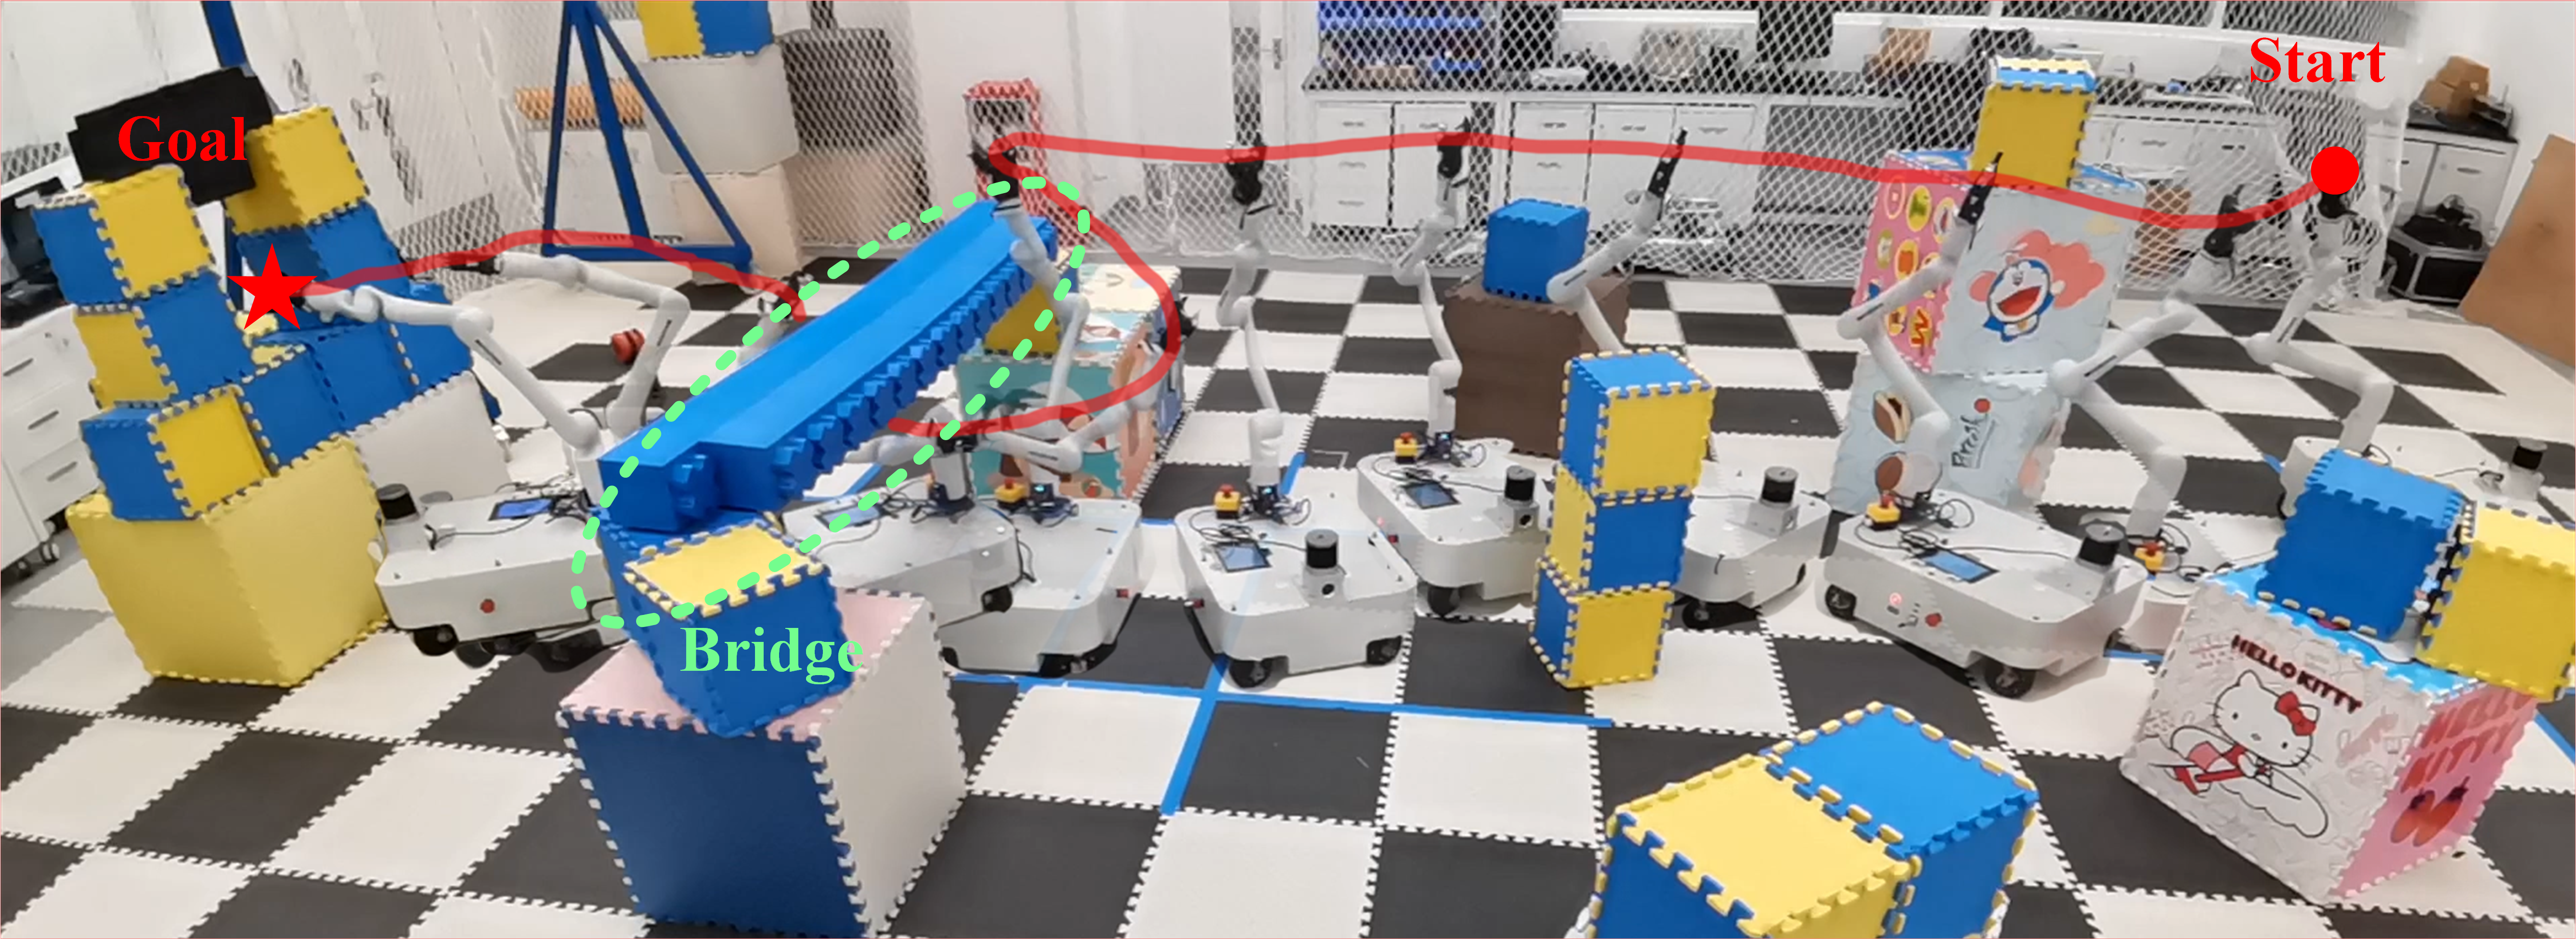
Interactive navigation framework for legged manipulators, featuring an active arm-pushing mechanism
IEEE Robotics and Automation Letters (RA-L), 2025
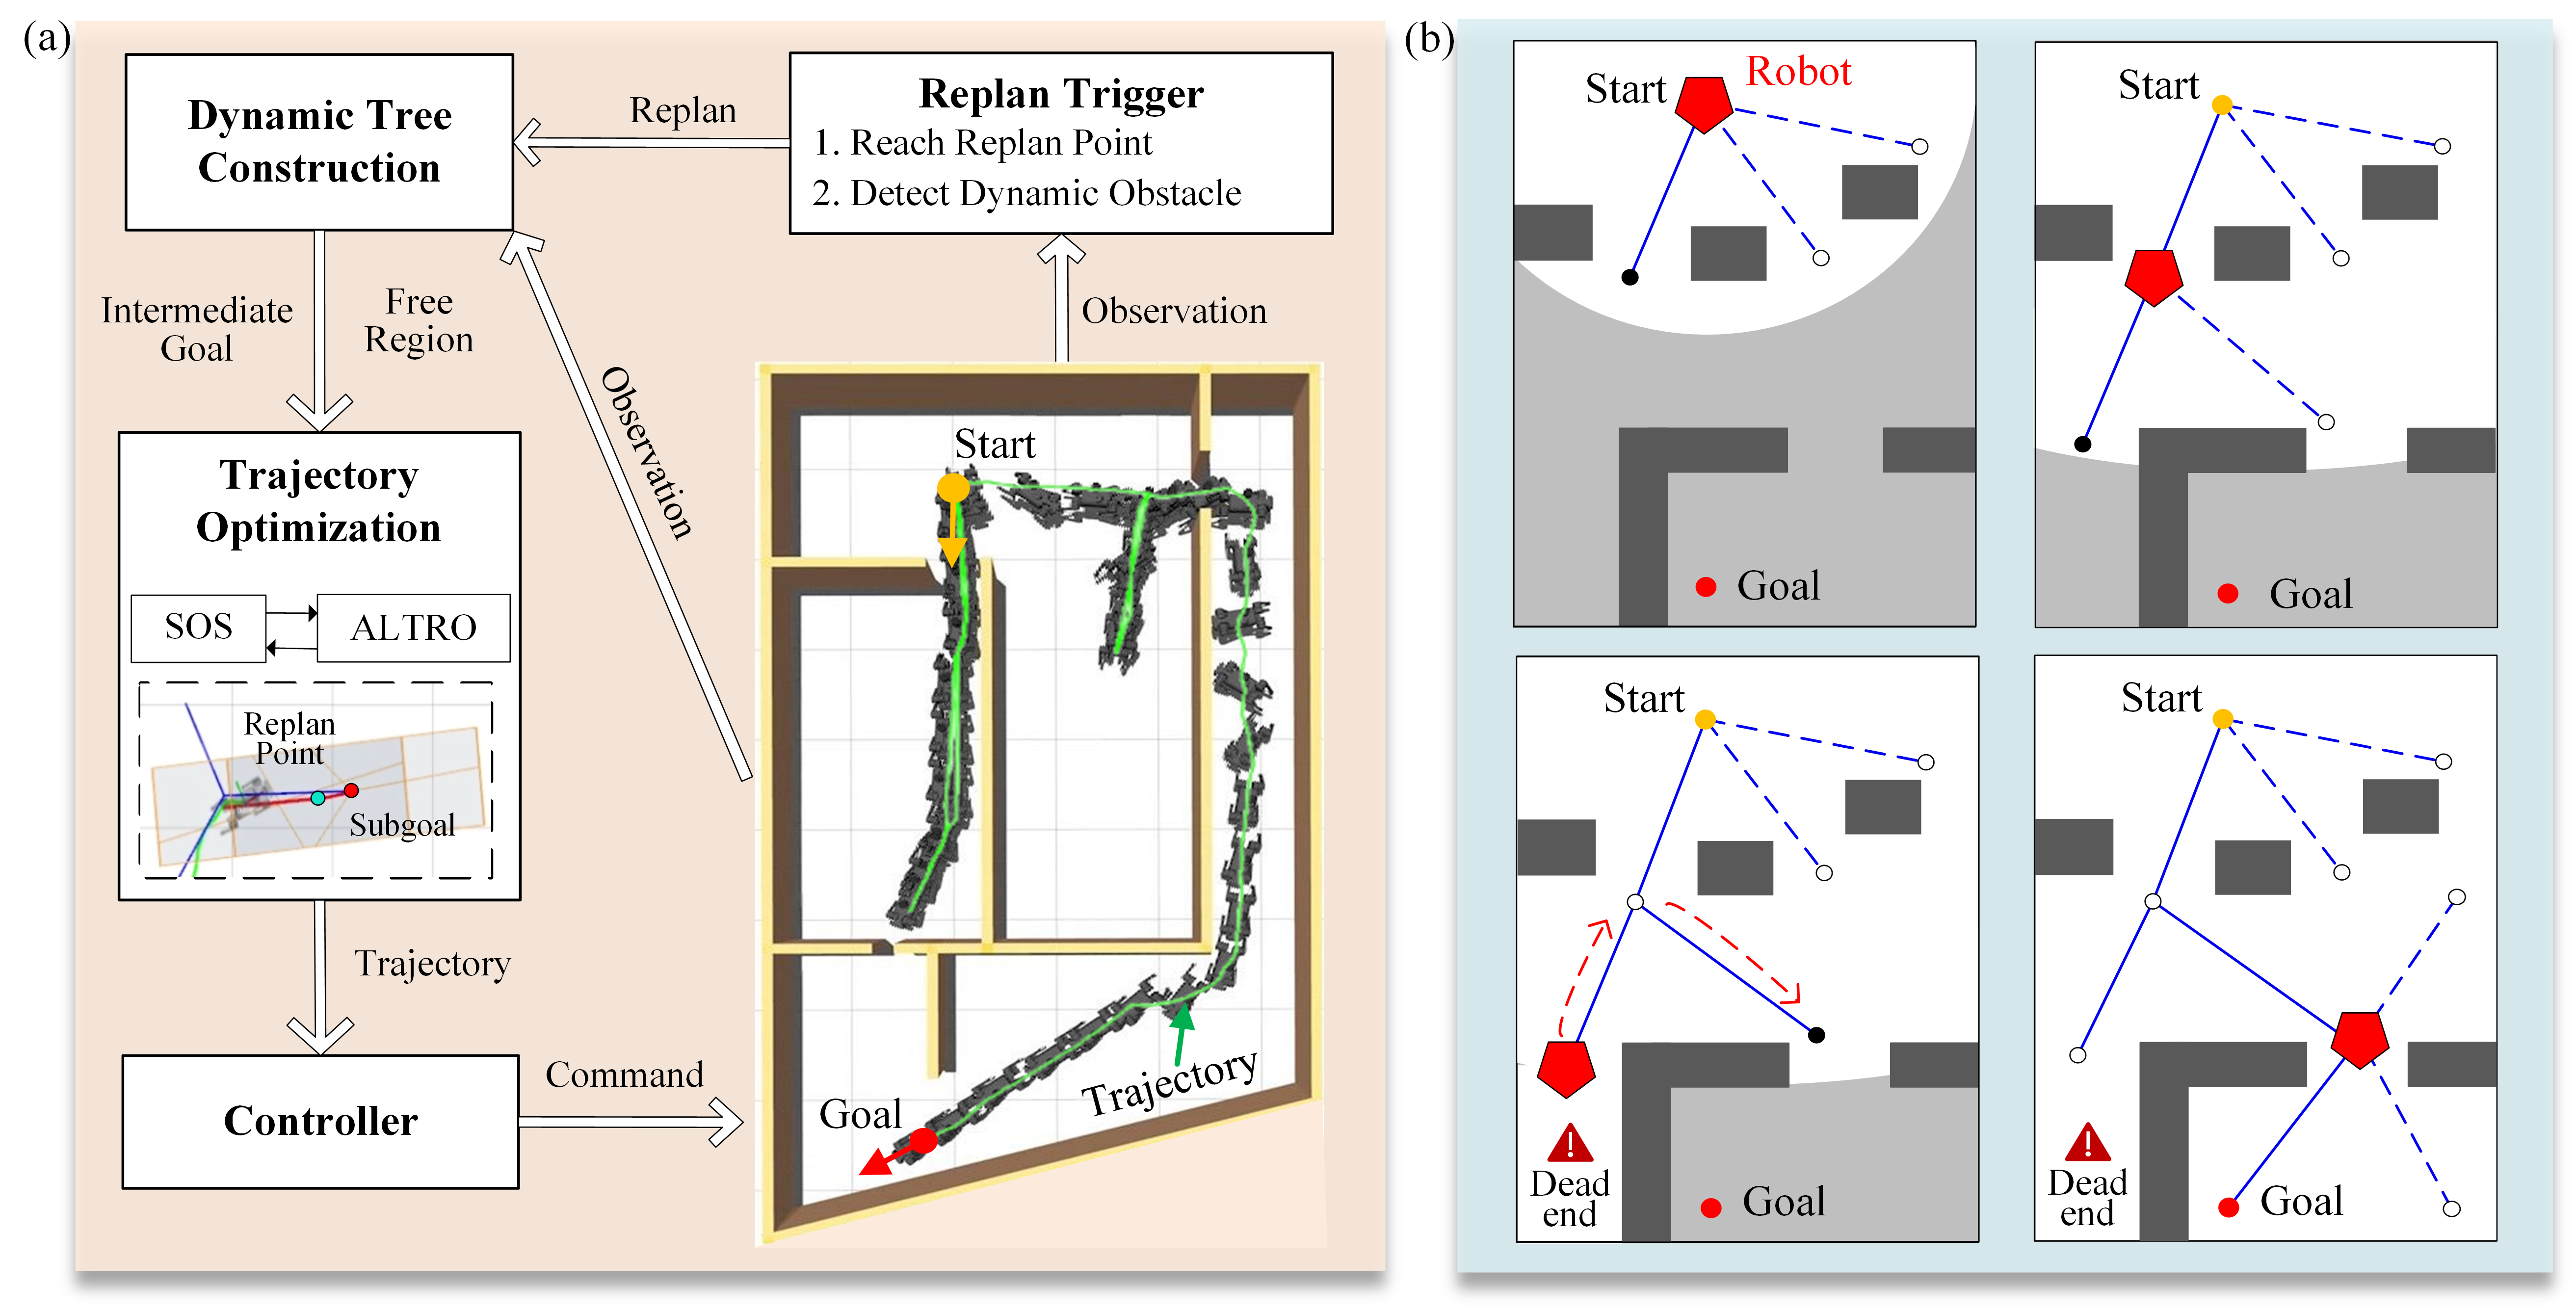
Robot navigation in cluttered and unknown environments with tree of free regions
IEEE Robotics and Automation Letters (RA-L), 2025
Reactive Control for Mobile Manipulators with Whole-Body Safety in Complex Environments
IEEE/ASME transactions on mechatronics, 2024
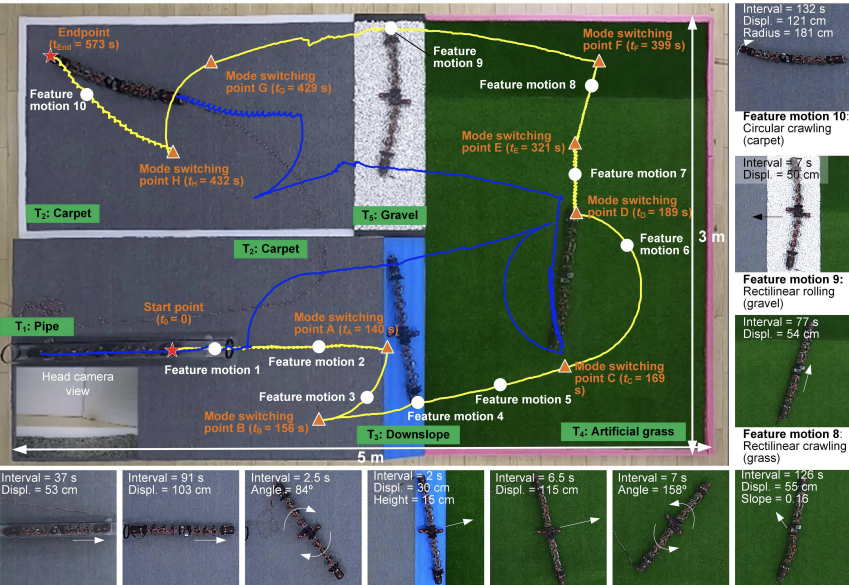
A multimodal metameric earthworm-like robot

International Journal of Mechanical Sciences, Q1, Top , 2023
This paper presents a new design and prototype of a Worm-Snake-Inspired Metameric robot with multi-modal locomotion capability.

IEEE International Conference on Robotics and Biomimetics (ROBIO), 2022
Path planning for the robot with multi-modal locomotion capability.